
In a radiological environment, sometimes the most useful thing a robot can do is simple: go where you would rather not send a person.
Imagine an abnormal radiation reading inside a facility. Before a technician enters, a quadruped robot equipped with the appropriate detector could be sent ahead to take readings at multiple locations and return that data to the team outside. It could approach the suspected source, stop at predetermined points, collect measurements, and provide cameras and other sensors with a view of the surrounding environment. The team now has information it did not have before anyone makes a decision about human entry.
Or consider a routine survey in an area where every entry adds to a worker’s cumulative exposure. A radiation inspection robot could potentially follow the same inspection route repeatedly, carrying the same type of radiation detection equipment a person might otherwise carry. Instead of using a person’s allowable exposure time simply to collect data, personnel can remain at a safer distance and use the information the robot brings back to plan what happens next.
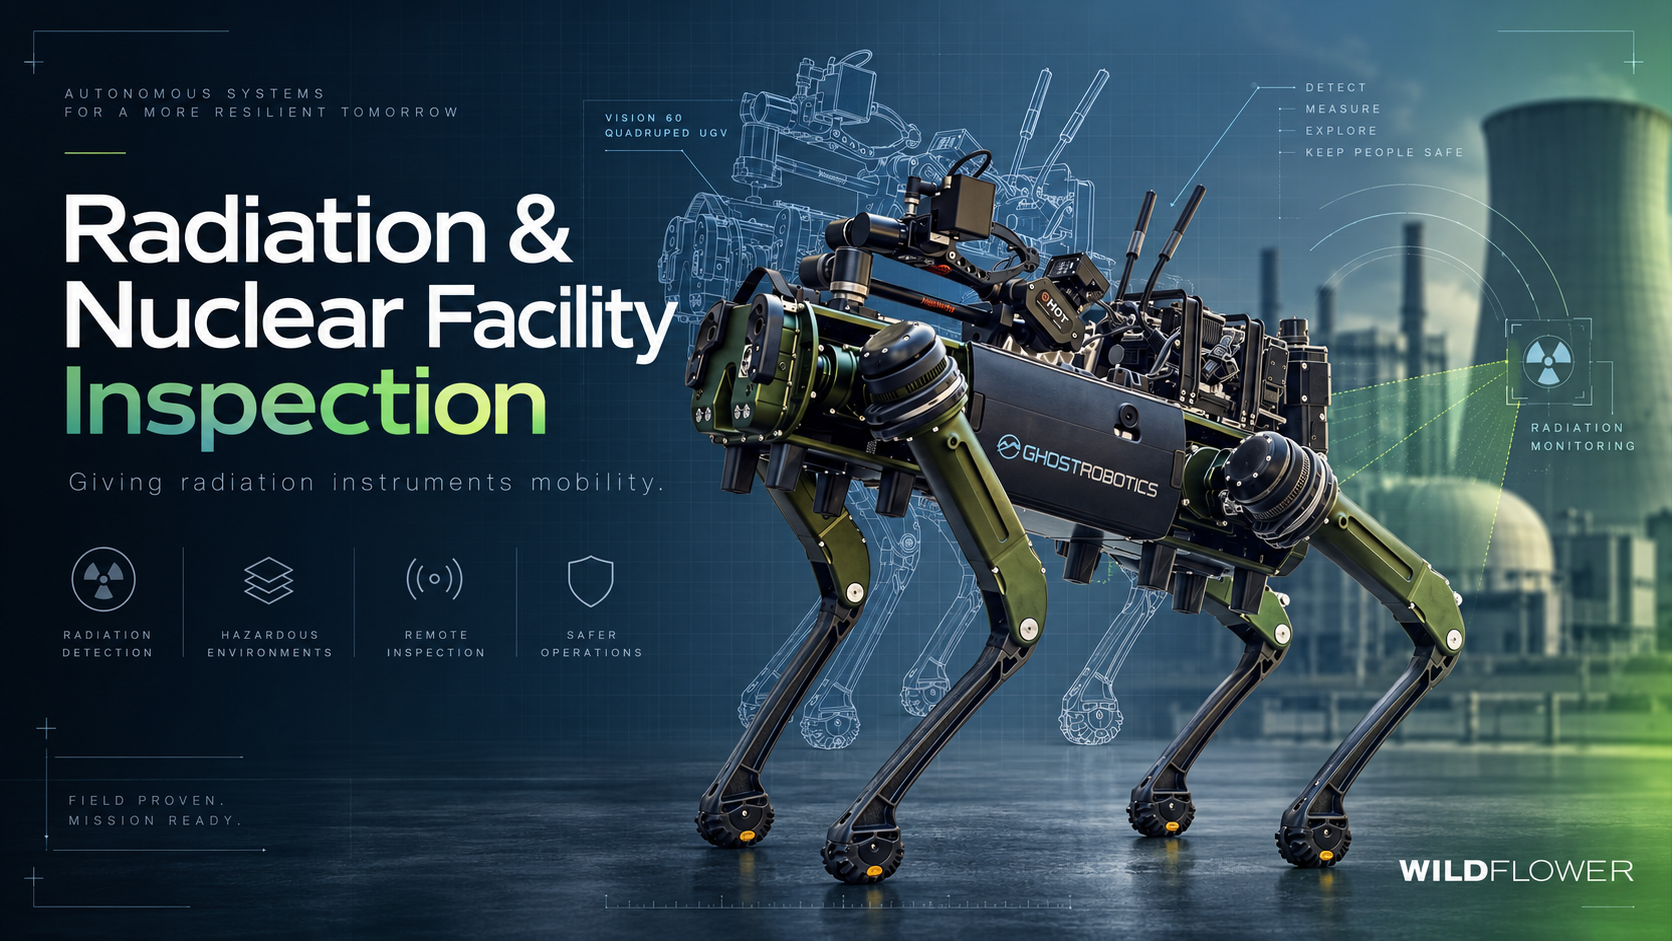
Quadruped robots can support radiation and nuclear facility inspection by carrying radiation detectors, cameras, thermal imaging, LiDAR, and other sensors into areas where human access is hazardous or limited. A platform such as the Ghost Robotics Vision 60 can provide the mobility and standoff needed to collect readings, inspect equipment, document conditions, and return information to personnel at a safer distance. The robot itself does not detect radiation; its value is carrying the appropriate detection equipment into difficult or hazardous environments and integrating that equipment into a usable remote inspection system.
That is where quadruped robots such as the Ghost Robotics Vision 60 become interesting for nuclear and radiological work. The robot is not the radiation detector. It gives the detector mobility.
A quadruped robot does not detect radiation on its own. Radiation detection comes from the payload it carries. Depending on the mission, that could include equipment for measuring radiation levels, identifying particular radioactive materials, or detecting certain nuclear materials.
The Vision 60 is designed as a modular platform that can carry mission-specific sensors and other payloads. For radiological work, that creates the possibility of taking instruments that normally depend on a person for mobility and putting them on a platform that can enter the environment instead.
The distinction is important. A robot carrying a radiation detector should not automatically be described as a proven nuclear inspection system. The detector has to be selected for the mission, integrated with the platform, tested, and incorporated into a usable data and communications workflow.
But the underlying idea is straightforward: if an instrument can collect useful information remotely, a mobile robot may be able to take that instrument to the place where the information is needed.
That changes what teams can consider doing from a distance.
A radiation inspection robot can carry detection equipment into a hazardous area, collect measurements at designated locations, and return that information remotely. Depending on its payloads, it could also provide visual, thermal, or mapping data that helps personnel understand the conditions surrounding those measurements.
Consider the problem of finding out what conditions look like beyond a known safe point. A robot can move progressively farther into the area while its radiation payload takes readings. Instead of sending someone forward with a handheld instrument to discover where conditions change, the team could receive measurements remotely and use them to make a better-informed entry plan.
For another mission, the objective might be repeatability rather than emergency response. A robot can return to established measurement locations on an inspection route, allowing personnel to compare readings over time without requiring the same level of repeated human access.
There are other possibilities. A radiation sensor could be paired with visual cameras so operators can associate an elevated reading with what they are seeing. Thermal imaging could provide another layer of information. LiDAR could help document the physical environment. Depending on the sensors, integration, and software involved, data from multiple sources could eventually contribute to a more useful picture of conditions inside the space.
In other words, the mission does not have to be simply “go in and tell us whether radiation is present.“
It might be:
Where are radiation levels changing?
What is physically located near an elevated reading?
Can we survey the area before sending in personnel?
Can we collect measurements at the same locations again tomorrow?
Can we inspect an area after an event before determining the appropriate human response?
Can we collect several kinds of information during one robotic inspection?
Those are much more interesting questions because they begin with the actual job rather than with the robot.
 How can robots reduce radiation exposure for workers?
Robots can reduce radiation exposure by performing inspection and data-collection tasks that would otherwise require a person to enter or remain in a radiological environment. They can also provide information before human entry, allowing teams to better understand conditions and plan the work that still requires personnel.
That does not mean the objective is necessarily to eliminate people from the work. Often, the more practical goal is to use the robot for the portion of the mission that does not require a person to be physically present.
A robot might perform the initial survey, for example, while experienced personnel interpret the data and determine what needs to happen next. It might collect readings along a route before a technician enters. Or it might perform repetitive monitoring so that human exposure is reserved for work that actually requires human judgment or manipulation. The result is a different division of labor: send the machine to gather information when possible, and send the person when the person’s presence is necessary.
A quadruped robot is most useful when an inspection route includes terrain or obstacles that make wheeled or tracked movement difficult. If the entire mission takes place on a smooth, unobstructed floor, a simpler mobile platform may be entirely adequate.
The value of a quadruped appears when the route starts looking more like a route designed for people than for machines. Stairs, raised thresholds, grating, debris, narrow passages, uneven surfaces, and other obstacles can limit conventional ground robots. The Vision 60 is designed to traverse stairs and unstructured terrain and to hold position where a sensor needs to collect information. Its IP67-rated construction also supports operation in demanding environments.
That can matter in older facilities, industrial sites, damaged structures, and other spaces where the most important measurement point may not happen to sit at the end of a clean rolling path. Many of these same mobility advantages apply to robotic infrastructure inspection, where a robot may need to navigate stairs, obstacles, uneven surfaces, or difficult access points to reach the asset being inspected.Mobility is therefore not just about getting from one end of a building to another. It is about getting the sensor to the right place.
A radiation inspection robot can potentially combine mission-specific radiation detection equipment with cameras and other sensing technologies supported by the robotic platform. The appropriate payload depends on what the team needs to measure, see, locate, or document during the inspection.
The Vision 60 supports onboard sensing and computing as well as optional payloads and external communications. The current technical material identifies capabilities including RGB and time-of-flight sensing, thermal imaging and LiDAR options, along with interfaces for additional mission equipment.
That creates opportunities to combine different kinds of information during an inspection.
| Inspection need | What the robotic system could provide |
|---|---|
| Radiation survey | Carry the appropriate radiation detector to designated measurement points |
| Visual inspection | Return camera imagery from areas where human access is hazardous or limited |
| Thermal inspection | Add thermal imaging where temperature information is useful to the mission |
| Mapping | Use LiDAR or other supported sensing to document the physical environment |
| Repeat monitoring | Return to designated locations for repeated data collection |
| Preliminary assessment | Gather information about conditions before personnel enter |
A team responding to an unexpected condition, for example, may want radiation measurements, but it may also want a visual inspection of the area. Is equipment damaged? Is there debris blocking access? Is a valve in the expected position? Has something changed since the last inspection? Can the robot see a label, gauge, pipe, container, or other feature that helps personnel understand what they are dealing with?
A more advanced configuration might combine radiation readings with position or mapping data so measurements can be associated with locations within the inspected area.
The exact configuration would depend on the mission. That is the point. The useful question is not simply, “Which radiation detector fits on the robot?” It is, “What information do we need the robot to bring back?“

