
On a modern battlefield, GPS is enormously useful. It is also something the warfighter cannot assume will always be available.
Buildings, terrain, tunnels, and subterranean spaces can block or degrade satellite signals. In a contested environment, an adversary may deliberately jam or spoof them. The Department of Defense has publicly described GPS and unmanned systems as targets of electromagnetic interference, while the Army has documented the operational consequences of losing GPS during unmanned ISR missions.
If the GPS signal disappears, the mission cannot simply disappear with it.
GPS-denied navigation allows a quadruped robot to continue estimating its position, avoiding obstacles, and moving through an environment when satellite positioning is weak, unavailable, or intentionally disrupted. On the Vision 60, LiDAR can provide local position estimation and obstacle awareness indoors, underground, and in other GPS-constrained environments, while the platform’s autonomy tools support waypoint missions, route playback, and integration with third-party autonomous software.
For military users, that is not simply a navigation feature. It determines where an unmanned ground system can remain useful when conditions stop being ideal.
GPS-denied navigation is the ability of a system to continue navigating when satellite-based positioning is unavailable or unreliable. Rather than depending exclusively on coordinates supplied by satellites, the robot uses information available locally to understand its surroundings and estimate its movement through them.
For Vision 60, the documented LiDAR payload provides a 360-degree horizontal field of view and generates point-cloud information that can support position estimation in GPS-constrained environments. Ghost specifically identifies indoor and subterranean operation as examples and states that the LiDAR data can work with Ghost Robotics waypoint capabilities or be integrated into third-party autonomous software through ROS2.
In practical terms, the physical world around the robot becomes part of the navigation solution. Walls, passages, obstacles, terrain, structures, and other features provide information the system can use when satellite positioning is no longer sufficient.
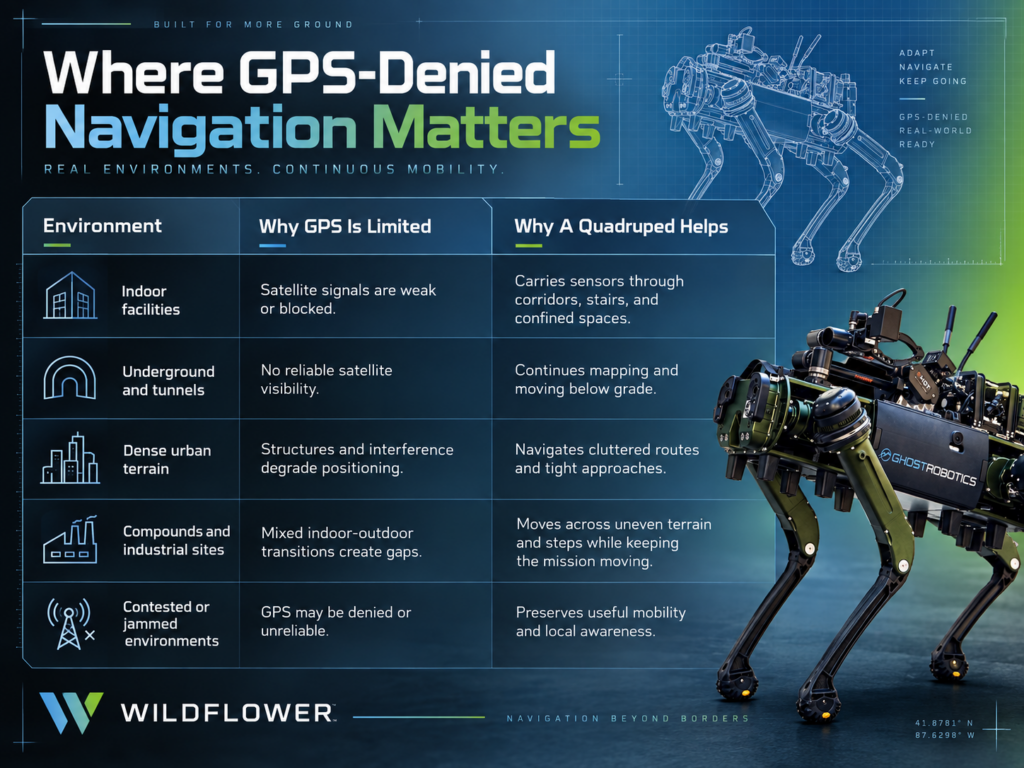
That has obvious applications in buildings, tunnels, underground facilities, dense urban terrain, industrial sites, and disaster environments. For military users, however, there is an additional problem: GPS may not simply be unavailable because of geography. Someone may be actively trying to take it away.
 Why does GPS denial matter on the battlefield?
GPS denial matters because position, navigation, timing, communications, ISR, and unmanned systems are all operating within an increasingly contested electromagnetic environment.
The Army has documented how GPS jamming can directly affect unmanned ISR. In one training example, a Shadow UAS lost GPS in a contested environment and was forced to return to base, temporarily costing the brigade an ISR asset. Army guidance has consequently stressed the need to plan for degraded and denied GPS rather than treating satellite access as a constant. More recent Army work likewise describes jamming and spoofing as threats to reliable positioning and navigation. This is one reason GPS-denied navigation has become increasingly important within combat and battlefield robotics: an unmanned system has to remain useful even when the electromagnetic environment is actively contested.
For a tactical ground robot, the consequences are easy to imagine. The platform may be moving ahead of personnel, carrying surveillance equipment, checking a route, entering a building, moving through a tunnel, patrolling an installation, or transporting a mission-specific sensor. If navigation depends entirely on an uninterrupted GPS signal, its usefulness can decline precisely when the environment becomes most contested.
The goal of GPS-denied navigation is therefore not to make GPS irrelevant. It is to give the system another way to remain useful when GPS cannot be relied upon.
Vision 60 combines onboard sensing, perception-aided mobility, mission automation, and optional LiDAR-based position estimation rather than relying on a single navigation input.
Ghost Robotics’ LiDAR payload is specifically designed to provide position estimation where GPS is weak or nonexistent. During autonomous patrols and waypoint routes, it can also identify moving and static obstacles and support navigation around them. The data is accessible through ROS2 and integrates with Ghost’s autonomy software and Mission Manager. (The same resilience matters for base and installation security, where patrol routes may pass through buildings, covered areas, dense infrastructure, or other locations with unreliable satellite reception.)
The Vision 60 platform adds other mobility and autonomy functions. Its specifications include front and rear collision avoidance, perception-aided stair climbing, footstep planning over curbs and grated surfaces, record-and-playback route automation, and scriptable mission control. The platform also incorporates RGB and depth sensors and supports interfaces including ROS, ROS2, MAVLink, ATAK, and JSON Mission Control.
The important point is that GPS-denied navigation is not one sensor doing one job. It is the interaction among sensing, localization, mobility, autonomy software, communications, and the mission itself.
LiDAR gives the robot a way to measure the physical environment around it and produce a three-dimensional representation of nearby structures and obstacles. The Vision 60 LiDAR payload provides 360-degree horizontal coverage, a 45-degree vertical field of view, and point-cloud data with centimeter-scale specified range accuracy under defined conditions. Ghost lists a detection range of 100 meters at greater than 90 percent probability under the stated target and lighting parameters.
Those specifications are more useful when translated into a mission.
Consider a quadruped moving into the lower level of a structure where GPS reception has disappeared. It still needs to recognize walls and passages, identify whether the intended route is blocked, detect an obstacle that was not present when the route was planned, and determine how its position is changing relative to the environment it has already observed.
LiDAR provides information the autonomy system can use to address those local navigation problems. The value is not that the robot possesses a sophisticated laser sensor. The value is that the robot can continue interpreting the physical space around it when coordinates from above are no longer enough.
GPS-denied navigation can allow reconnaissance sensors to keep moving into locations where reliable satellite positioning is unavailable.
Vision 60 can carry a PTZ camera designed for ISR, perimeter security, surveillance, law enforcement, and industrial inspection. Ghost’s current camera specification provides 33× optical zoom, continuous 360-degree pan, infrared illumination to 50 meters, day/night imaging, and programmable patrol presets.
Combine that sensing capability with a mobile platform able to operate in a GPS-constrained environment, and the mission becomes more interesting. A quadruped could potentially carry the camera through a building, enclosed installation, tunnel system, dense urban site, or other ground-level environment while providing imagery to personnel who remain farther back.
The useful capability is not simply a robot with a camera. It is a mobile ISR sensor whose movement does not have to end when satellite navigation becomes unreliable.
That distinction also helps explain where a quadruped fits alongside other unmanned systems. UAVs have transformed battlefield observation and remain exceptionally useful for aerial reconnaissance. A quadruped approaches the problem from ground level, entering structures, moving underneath cover, traversing passages, and positioning a sensor inside spaces an airborne platform may not be able to occupy.
Knowing where the robot is solves only half of the navigation problem. The platform must also be physically capable of reaching the destination.
Vision 60’s four-legged architecture is designed to traverse stairs, slopes, rocks, mud, sand, snow, debris, and mixed indoor and outdoor terrain. Its autonomy capabilities include footstep planning over curbs and grated surfaces, and the platform can recover after slipping or falling.
That matters because GPS-constrained environments are often physically complicated environments as well. A subterranean route may contain stairs, debris, abrupt elevation changes, grating, or narrow passages. An urban structure may contain thresholds, damaged flooring, obstacles, stairwells, and routes that no longer resemble the available floor plan.
Navigation therefore has two simultaneous requirements: the robot must determine its position within the environment, and it must determine how to move through the terrain in front of it. For a tactical ground system, localization without mobility is of limited value.
Loss of GPS and loss of useful optical sensing are separate problems, but a fielded system may encounter both.
Ghost Robotics’ proprietary Blind Mode allows Vision 60 to continue moving when its optical sensors are partially or completely obstructed by conditions such as mud, rain, snow, tall grass, or direct sunlight. This should not be confused with LiDAR-based GPS-denied position estimation, but together they illustrate an important principle in tactical robotics: resilience depends on avoiding a single point of failure wherever practical.
A battlefield system may encounter poor visibility, damaged terrain, GPS interference, obstructed communications, and unexpected obstacles during the same mission. The more the system can draw from different sensing and mobility capabilities, the more options operators retain when conditions deteriorate.
 How could GPS-denied navigation support CBRN reconnaissance?
GPS-denied navigation can help move chemical, biological, radiological, and nuclear sensing equipment into enclosed or hazardous areas where satellite positioning may be poor and sending personnel forward may be undesirable.
Ghost’s CBRN Hub is a modular Vision 60 payload that supports configurable sensor packages, real-time monitoring, additional onboard computing, and communications passthrough for operator-selected radios. Its documented sensor options include chemical-agent detection, toxic-industrial-chemical monitoring, and gamma radiation measurement.
Imagine a suspected hazardous area within a structure or subterranean facility. The mission is not merely to put a detector on a robot. The platform must carry the detector through the environment, maintain useful positioning, negotiate obstacles, transmit information, and reach the place where the measurement matters.
This is closely related to radiation and nuclear facility inspection, where mobility allows specialized instrumentation to collect information without requiring a person to carry it into the environment. In a tactical CBRN mission, the operating conditions and decision cycle are different, but the underlying systems problem is similar.
GPS denial and communications loss are not the same problem. A robot may be able to estimate its position without GPS while still relying on a communications link for operator control, mission updates, or sensor feeds.
Vision 60 includes integrated Wi-Fi and 4G/LTE and supports external radios through its Ethernet architecture. Ghost’s CBRN Hub also provides communications passthrough and specifically identifies MANET radio integration as an option.
That flexibility allows the communications stack to be designed around the mission, but it also makes requirements definition important. A tactical user should consider what the platform must do if GPS disappears, what must happen if the communications link degrades, and what level of autonomous behavior should continue if both occur.
Those questions are much more useful than simply asking whether a robot is “GPS-denied capable.” A fielded capability has to define what the robot can still sense, decide, execute, and report when parts of the larger system become unavailable.
Vision 60 supports record-and-playback mission automation, waypoint-based operations, and LiDAR-assisted position estimation in GPS-constrained environments. Those capabilities create several useful tactical possibilities.
A unit might establish a repeatable patrol route through a compound, return the robot to designated observation points, conduct repeated security checks around an installation, or move through a previously characterized environment using local sensing rather than depending continuously on satellite positioning.
That does not mean route playback, GPS-denied localization, and fully autonomous mission execution are interchangeable terms. How independently the robot should operate depends on the mission, software configuration, terrain, communications, payload, command-and-control architecture, and level of human supervision required.
That is where systems integration becomes just as important as the robot itself.
An open architecture matters because the military does not field navigation in isolation. The robot has to coexist with sensors, radios, command-and-control systems, software, mission payloads, and other technologies already used by the force.
Vision 60 supports third-party sensors, communications equipment, payloads, and software through its SDK and interfaces that include ROS, ROS2, MAVLink, ATAK, Ethernet, and other mission-control capabilities. The LiDAR payload likewise exposes its data through ROS2, allowing that information to be used within Ghost software or integrated into third-party autonomy systems.
That makes the platform more useful as part of a larger tactical system. A mission might combine LiDAR for local position estimation, onboard perception for obstacle avoidance, quadruped mobility for difficult terrain, a PTZ or other EO/IR payload for ISR, tactical radios for communications, ATAK or another interface for command and control, and waypoint or record-playback capabilities for repeated movement.
| Mission requirement | Relevant capability |
|---|---|
| Positioning where GPS is unavailable | LiDAR-based local position estimation |
| Obstacle detection | LiDAR, depth sensing and perception |
| Difficult ground and structures | Quadruped mobility and footstep planning |
| Day/night observation | PTZ or other EO/IR payload |
| CBRN reconnaissance | Mission-specific detection payload |
| Tactical communications | Integrated or mission-selected external radios |
| Command and control | OCU, Mission Manager, ATAK or integrated software |
| Repeatable movement | Waypoint and record-playback mission tools |
The Vision 60 is the mobile platform underneath that stack. The battlefield capability comes from how those pieces are configured and integrated around the mission. Importatnly, GPS-independent mobility can also support search, rescue, and disaster response, particularly inside damaged buildings, tunnels, underground spaces, and other environments where satellite positioning may be unavailable.
Yes. Many environments deny GPS without hostile action.
Underground infrastructure, industrial facilities, warehouses, tunnels, large buildings, dense construction, and disaster sites can all interfere with satellite positioning. That makes the same technologies relevant to robotic infrastructure inspection, emergency response, hazardous-environment robotics, public safety, and critical-infrastructure missions.
The military application remains distinct because denial may be deliberate. In civilian use, the problem may be that GPS simply cannot reach the robot. In a contested environment, the system may need to continue operating while an adversary is actively attempting to disrupt a capability on which the force normally relies.
That changes GPS-denied navigation from a convenience into a question of operational resilience.
Yes, subject to the export requirements of the specific platform configuration, payloads, software, radios, destination, and end user.
Wildflower has decades of experience supplying technology to government customers and supporting mission requirements beyond the continental United States. Our ISO 9001 quality-management framework and experience working within applicable U.S. export-control requirements, including ITAR where applicable, support that international work.
There is also an important distinction between Wildflower’s export-compliance capability and the classification of Vision 60 itself. The current Vision 60 is identified as EAR99 and carries no ITAR restrictions. That does not automatically mean every possible Vision 60 configuration can be exported without review. A particular sensor, radio, software package, payload, end user, or destination may introduce different requirements.
For an allied buyer, the question is therefore not simply whether a robot can be shipped internationally. The complete mission configuration has to be evaluated as a system.
 What should a military buyer evaluate before fielding a GPS-denied quadruped?
The evaluation should begin with the mission.
Where does the robot need to operate? Why might GPS be unavailable there? Does it need to navigate a known route or explore an unfamiliar structure? Will it carry ISR, CBRN, communications, or another mission payload? Does it need to enter subterranean spaces, operate around buildings, patrol a perimeter, or move through damaged terrain?
The next question is what the robot must still accomplish after GPS becomes unreliable. That determines the required combination of local sensing, autonomy, communications, mission software, payload integration, operator control, route planning, and training.
A military buyer should also evaluate what happens when several conditions deteriorate at once. GPS may be degraded while communications are intermittent. Optical sensors may be obscured while terrain becomes more difficult. The robot may encounter an obstacle not present when the route was planned. Resilience is not demonstrated simply by removing GPS during a controlled test. It is demonstrated by understanding what the complete system can still accomplish when the operating environment stops cooperating.
That is the difference between purchasing a robot with a GPS-denied feature and fielding a robotic capability designed for a GPS-denied fight.
GPS has made precise navigation so familiar that it is easy to think of position as something a system simply knows. In a contested environment, that assumption has to change.
A quadruped operating without reliable GPS increasingly depends on local awareness. LiDAR provides information about surrounding structure. Depth sensors help identify obstacles. Perception and autonomy software interpret those inputs. Legged mobility lets the platform act on them in terrain designed for people rather than machines. Mission payloads then turn that mobility into reconnaissance, CBRN sensing, inspection, security, or another operational capability.
Wildflower has spent decades supplying technology to the warfighter and understands that battlefield systems are judged by what they contribute to the mission, not by an isolated technical specification. Our experience spans unmanned systems, communications, sensing, integration, and the realities of putting technology into operational environments.
With Vision 60, our role is to help customers determine what the mission requires, configure the platform and payloads around that requirement, integrate the supporting technologies, navigate procurement and export considerations, and support deployment and sustainment. For a broader look at platform capabilities, mission fit, integration, acquisition, and deployment considerations, see the Complete Federal Guide to Quadruped Robotics.
As the battlefield becomes more contested, unmanned systems will increasingly be judged by what they can continue to accomplish after a capability they normally depend on becomes unreliable. GPS-denied navigation is one part of building that resilience, and for a robot intended to move ahead of the warfighter, it is an increasingly important one.
Wildflower has spent more than 30 years supporting federal technology missions, with experience across defense, unmanned systems, communications, integration, procurement, and lifecycle support. Our team can help evaluate whether Vision 60 fits the mission, configure the right payloads and supporting technologies, and navigate the acquisition, compliance, deployment, and sustainment requirements that turn a robotic platform into an operational capability.

